Materialised Model
Overview
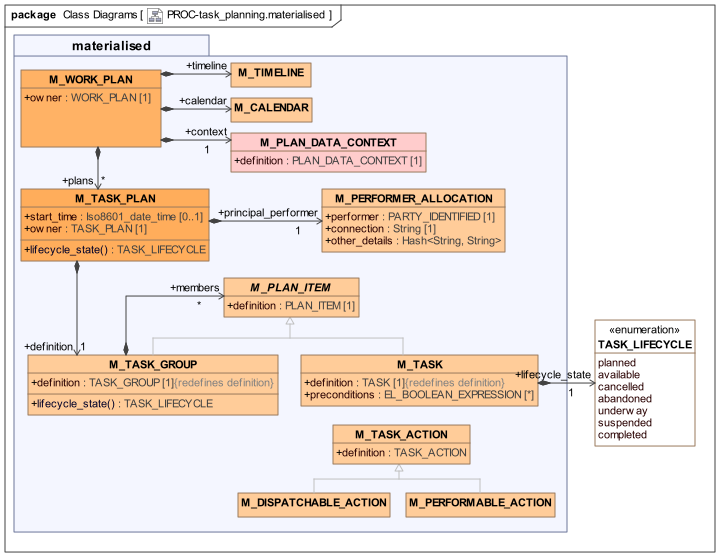
The Model overview figure shows a package proc.task_planning.materialised. This is a partial specification of classes that could be instantiated at Task Plan execution time to track Plan execution, and is provided as a guide to implementing a materialised form for runtime use. A minimal materialised model is described here, as a means of indicating some of the general issues that will be encountered in representation of the runtime form of a Plan definition. It should not be considered either normative or complete. The model is shown below.
Class Descriptions
M_WORK_PLAN Class
-
Definition
Class |
M_WORK_PLAN |
|
|---|---|---|
Description |
Materialised form of |
|
Attributes |
Signature |
Meaning |
0..1 |
plans: |
Member Plans. |
1..1 |
owner: |
Owning Work Plan definition. |
1..1 |
timeline: |
Materialised global timeline. |
1..1 |
calendar: |
Materialised global calendar. |
1..1 |
context: |
Materialised global context. |
M_TASK_PLAN Class
-
Definition
Class |
M_TASK_PLAN |
|
|---|---|---|
Description |
Root object of a materialised Task Plan structure, used in execution. |
|
Attributes |
Signature |
Meaning |
0..1 |
start_time: |
Nominal start time for the Task Plan as a whole. The timings of individual Tasks may be specified as offsets from this time, via |
1..1 |
definition: |
Root of run-time Task Plan Task structure. |
1..1 |
owner: |
Owning Task Plan definition. |
0..1 |
pending_callbacks: |
Reference list of all wait conditions in the Task Plan, and current status. |
1..1 |
principal_performer: |
Run-time principal performer - a person or other agent. |
Functions |
Signature |
Meaning |
1..1 |
lifecycle_state (): |
Lifecycle state of Task Plan, derived as a copy of the |
M_PERFORMER_ALLOCATION Class
-
Definition
Class |
M_PERFORMER_ALLOCATION |
|
|---|---|---|
Description |
Tracking information for a current performer allocation. |
|
Attributes |
Signature |
Meaning |
1..1 |
performer: |
Identity of allocated performer. |
1..1 |
connection: |
URI used to connect to performer (e.g. application, messaging channel) for notifications. |
1..1 |
Archetypable details. |
|
M_PLAN_ITEM Class
-
Definition
Class |
M_PLAN_ITEM (abstract) |
|
|---|---|---|
Description |
Abstract parent of materialised run-time types that correspond to design time |
|
Attributes |
Signature |
Meaning |
1..1 |
definition: |
Corresponding item from Task Plan definition. Redefined in descendants to the definition type corresponding to each runtime (RT_XXX) type. |
M_TASK_GROUP Class
-
Definition
Class |
M_TASK_GROUP |
|
|---|---|---|
Description |
Materialised form of |
|
Inherit |
||
Attributes |
Signature |
Meaning |
0..1 |
members: |
Member run-time items in group, mimicking structure of the corresponding definition group instance. |
1..1 |
definition: |
Reference to corresponding TASK_GROUP instance in Task Plan definition. |
Functions |
Signature |
Meaning |
1..1 |
lifecycle_state (): |
Effective lifecycle state, computed from the states of members of the group. |
M_TASK Class
-
Definition
Class |
M_TASK |
|
|---|---|---|
Description |
Materialised form of |
|
Inherit |
||
Attributes |
Signature |
Meaning |
1..1 |
lifecycle_state: |
Current lifecycle state of this Task at run-time. |
0..1 |
events: |
List of references to run-time events that have occurred on this Task. |
0..1 |
preconditions: |
Run-time form of preconditions on corresponding TASK in Task Plan definition. |
1..1 |
definition: |
Reference to corresponding TASK instance in Task Plan definition. |
M_TASK_ACTION Class
-
Definition
Class |
M_TASK_ACTION |
|
|---|---|---|
Description |
Materialised form of |
|
Attributes |
Signature |
Meaning |
1..1 |
definition: |
|
M_DISPATCHABLE_ACTION Class
-
Definition
Class |
M_DISPATCHABLE_ACTION |
|
|---|---|---|
Description |
Materialised form of |
|
Inherit |
||
M_PERFORMABLE_ACTION Class
-
Definition
Class |
M_PERFORMABLE_ACTION |
|
|---|---|---|
Description |
Materialised form of |
|
Inherit |
||